
Sorry.
You are not permitted to access the full text of articles.
If you have any questions about permissions,
please contact the Society.
죄송합니다.
회원님은 논문 이용 권한이 없습니다.
권한 관련 문의는 학회로 부탁 드립니다.
Current Issue
Volume 21(3); August 2026
-
Yeonsoo Park, Gunwoo Kim, Sung Gwan Park, Chang Joo Lee, Sungsoo Rhim
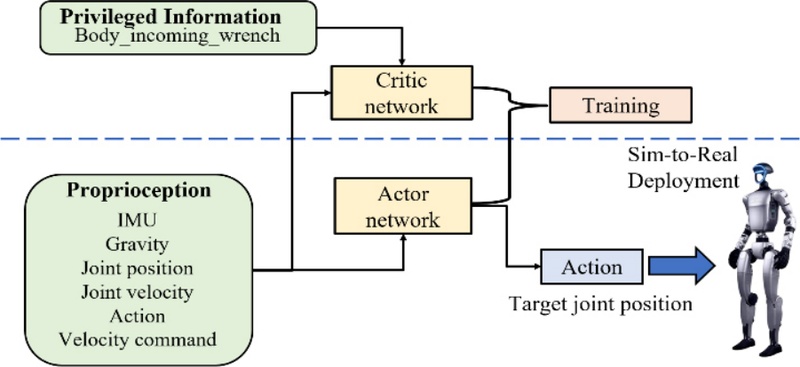
Humanoid robots operating in human environments must safely respond to physical human-robot interactions while maintaining stable locomotion. Conventional reinf...
-
Yonghyun Jo, Kwanwoo Lee, Gyeongjae Park, Seohyeon Lim, Jaeyong Shin, Hyunjun Choi, Sanghyuk Park, Jaeheung Park, SungMoon Hur
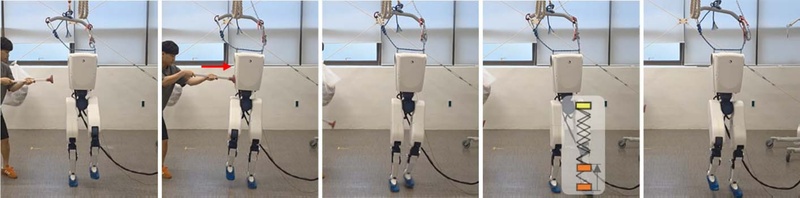
This paper presents a contact force-aware reinforcement learning framework for compliant humanoid bipedal walking. The framework estimates foot contact forces f...
-
Development of QP Based Posture Controller for Wheeled Bipedal Robot with High DoF
Junyeon Namgung, Baek-Kyu Cho
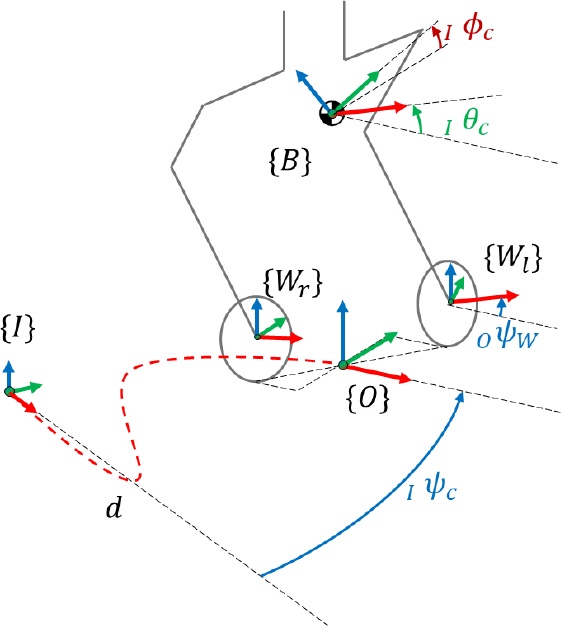
This paper presents a quadratic programming (QP)-based posture controller for Legway, a wheeled bipedal robot with a 10-DOF configuration in Wheel Mode. A linea...
-
Seong-Hyeon Ryu, Jung-Yup Kim
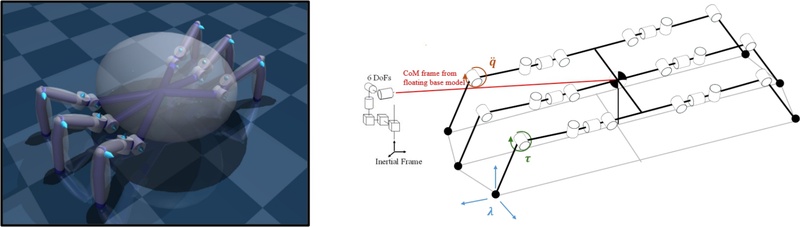
In this paper, we propose a set-based whole-body inverse-dynamics posture control framework for a multi-legged robot whose legs possess redundant degrees of fre...
-
Ha Jin Park, Ki-In Na
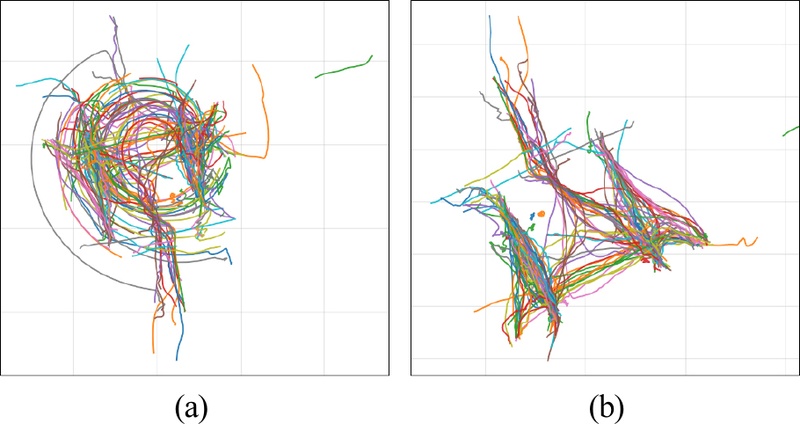
Predicting pedestrian trajectories is essential for safe mobile robot navigation in human-shared environments. Most existing models are trained on Bird’s-Eye-Vi...
-
A Biomimetic 3-DOF Humanoid Neck Design with Hybrid Gear-Linear Actuator Mechanism
Chanhyuk Moon, Juhyun Kim, Dongjun Kim, Eunho Sung, Woongbae Kim, Jaeheung Park
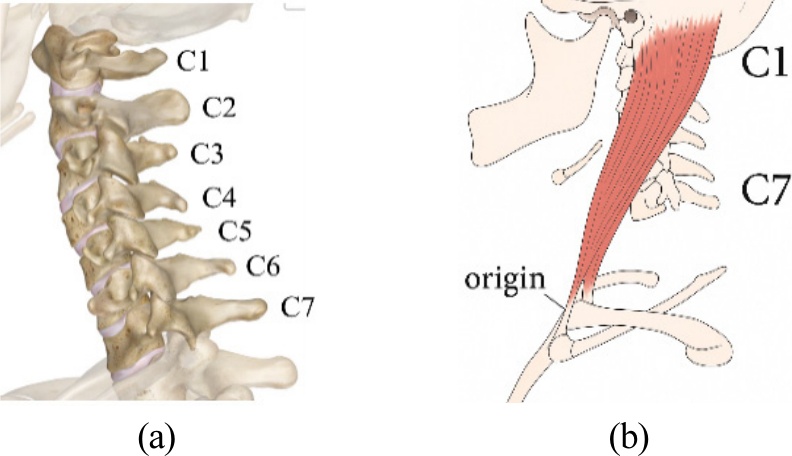
This paper presents a 3-degree-of-freedom humanoid neck mechanism that mimics human cervical motion using a differential gearbox and a linear actuator (LA). The...
-
Design of an Independent 3-DOF Flexion Kinesthetic Haptic Interface using Electrostatic Clutches
Nakhyeong Lee, Jihyeong Ma, Seohee Kong, Jongseok Nam, Ki-Uk Kyung
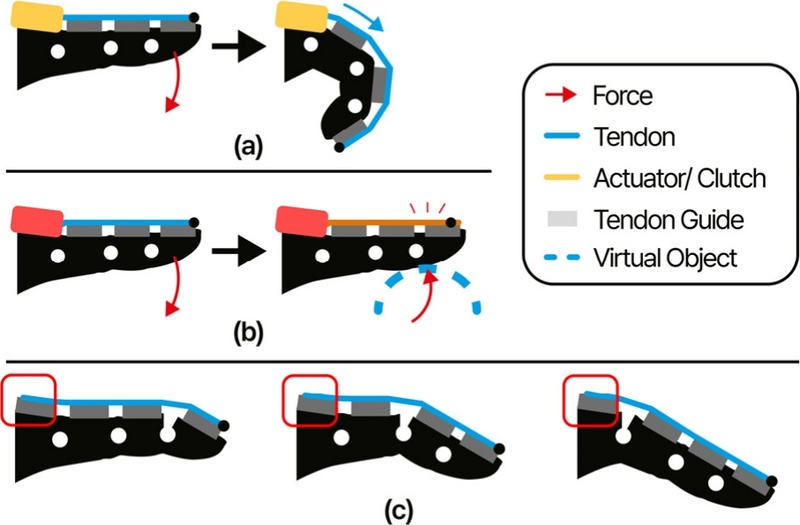
This study presents a kinesthetic haptic interface capable of independently constraining 3-DOF finger flexion using miniaturized electrostatic clutches. Convent...
-
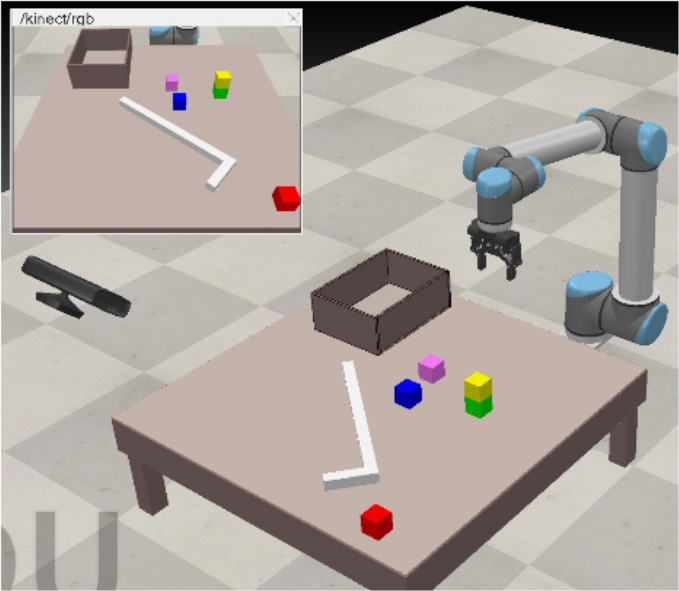
Context-Driven Task and Motion Planning with Language Models
Jinhwi Lee
This paper presents a task planning framework for autonomous robots that combines Large Language Models (LLMs) and Vision-Language Models (VLMs) to enable conte...
-
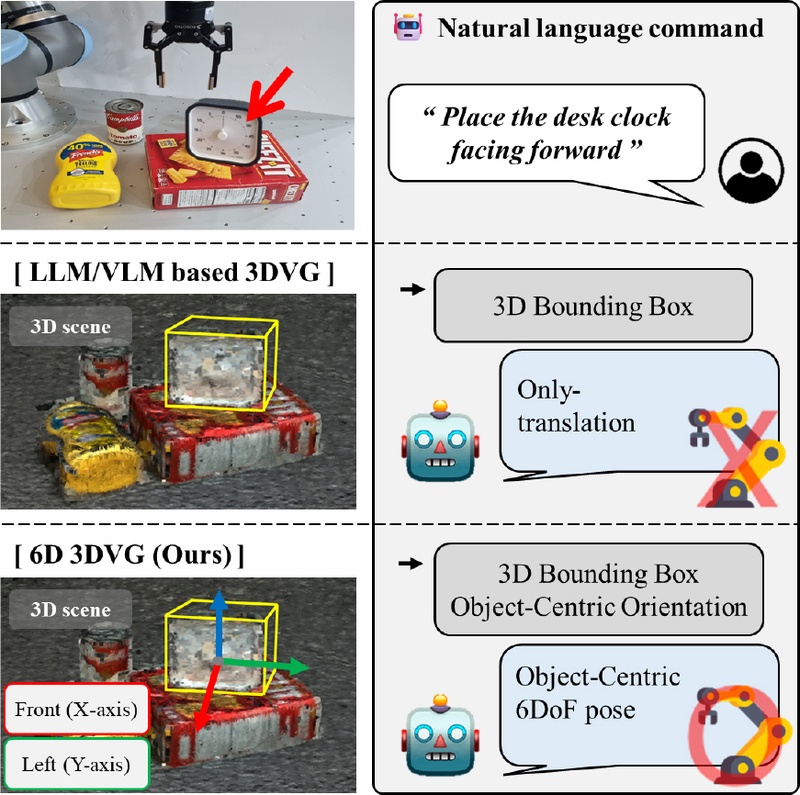
VLM-based Object-centric 6DoF 3D Visual Grounding
Seongyeop Lee, Hyunsoo Shin, Gyubeom Jo, Ji-Hun Bae, Sungon Lee
3D Visual Grounding aims to localize target objects in 3D scenes from natural language descriptions. Existing methods mainly provide object location information...
-
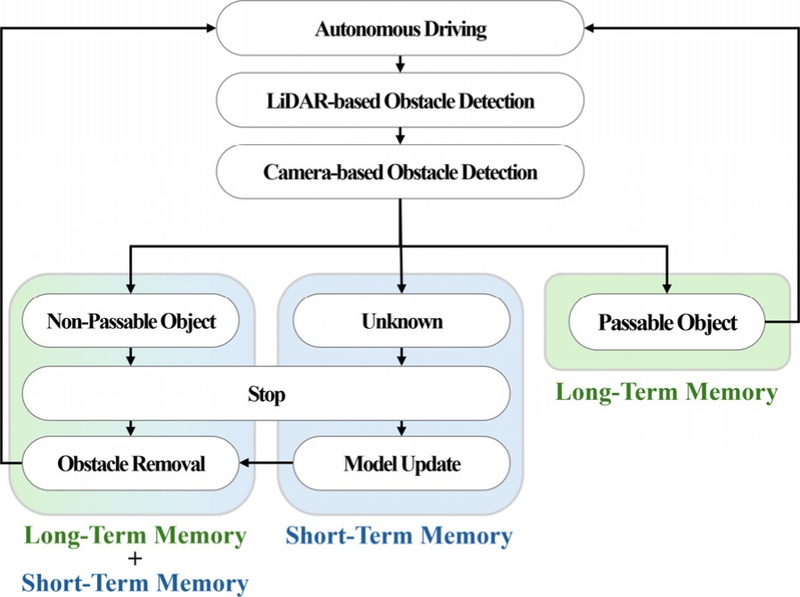
Adaptive Object Detection with Long- and Short-Term Memory via YOLOE Text–Free Model Collaboration
Jiho Kim, Jeonghoon Kwak, Dohyun Kyoung, Jaewan Koo, Byoung-Woo Gam, Joonwoo Lee, Kap-Ho Seo
Autonomous robots often operate in semi-structured environments such as orchards and warehouses, where unpredictable obstacles frequently appear. Conventional d...
Journal of Korea Robotics Society
· Journal Abbreviation : ‘J. Korea Robot.Soc’
· Frequency : Quarterly
· DOI Prefix : 10.7746/jkros
· ISSN : 1975-6291 (Print)
· ISSN : 2287-3961 (Online)
· Year of Launching : 2006
· Publisher : Korea Robotics Society
· Indexed/Tracked/Covered By :
· Frequency : Quarterly
· DOI Prefix : 10.7746/jkros
· ISSN : 1975-6291 (Print)
· ISSN : 2287-3961 (Online)
· Year of Launching : 2006
· Publisher : Korea Robotics Society
· Indexed/Tracked/Covered By :
Copyright © KOREA ROBOTICS SOCIETY. All rights reserved.
#504, The Korea Science and Technology Center, (635-4,Yeoksam-dong)22